

接收 cmd_vel
需要:uBotROS 0.1.x(含依赖 uBotCore、uBotSensor)
用 uBot ROS Velocity Command 接收 ROS 2 的 cmd_vel 速度指令,换算成 UE 的轴向后交给能执行它的对象。
组件订阅 geometry_msgs/msg/Twist,每收到一条有效指令就触发 On Velocity Command。没有现成的执行器时,可以直接在蓝图里处理:
连线:
- On Velocity Command (CmdVel) 的 执行,连到 Print String 的 执行
- On Velocity Command (CmdVel) 的 Command,连到 Break UBot Velocity Command 的 UBot Velocity Command
- Break UBot Velocity Command 的 Linear Velocity Meters Per Second,连到 Vector Length 的 A
- Vector Length 的 Return Value,连到 To String (Float) 的 In Double
- To String (Float) 的 Return Value,连到 Print String 的 In String
- 指令已经换算成 UE 的机体系轴向,线速度单位是 m/s。
On Velocity Command (CmdVel)
uBot ROS Velocity Command · UBotROS
每条有效指令换算、限速之后触发,有没有目标都触发,Command 是结果。
输出
- 执行
- Command
UBot Velocity Command结构体
查看参考UUBotROSVelocityCommandComponent.OnVelocityCommand
Break UBot Velocity Command
UBotCore
把 UBot Velocity Command 拆成线速度、角速度、时间戳和来源。
输入
- UBot Velocity Command
UBot Velocity Command结构体
输出
- Linear Velocity Meters Per Second
Vector - Angular Velocity Radians Per Second
Vector - Timestamp Seconds
Float (double) - Source
Name
查看参考Break:FUBotVelocityCommand
Vector Length
UE 引擎 · 中文界面:向量长度
Returns the length of the vector
输入
- A
Vector
输出
- Return Value
Float (double)
查看参考UKismetMathLibrary.VSize
To String (Float)
UE 引擎 · 中文界面:转换为字符串(浮点)
Converts a double value to a string
输入
- In Double
Float (double)
输出
- Return Value
String
查看参考UKismetStringLibrary.Conv_DoubleToString
Print String
UE 引擎 · 中文界面:打印字符串
Prints a string to the log, and optionally, to the screen If Print To Log is true, it will be visible in the Output Log window. Otherwise it will be logged only as 'Verbose', so it generally won't show up.
输入
- 执行
- In String
String - Print to Screen
Boolean - Print to Log
Boolean - Text Color
Linear Color结构体 - Duration
Float - Key
Name
输出
- 执行
查看参考UKismetSystemLibrary.PrintString
-
添加组件
在要被驱动的 Actor 上,点「Components」面板的「Add」,搜索
uBot ROS Velocity Command,重命名为CmdVel。Auto Start Receiver默认开启,Begin Play时开始订阅。属性在「Details」面板的「U Bot > ROS > Velocity Command」下,限速在其中的 Limits 子类别里: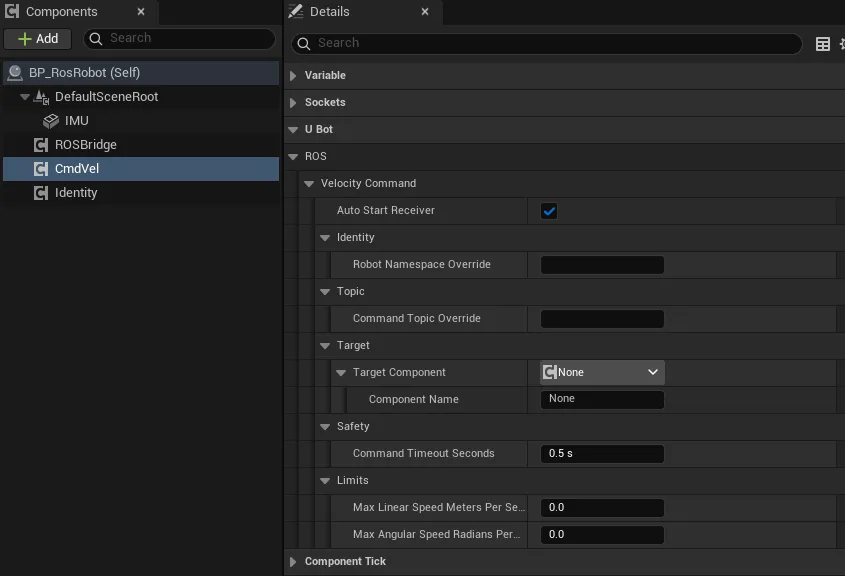
-
确定话题
话题是
/<namespace>/cmd_vel,命名空间的规则与 Sensor Bridge 相同:取uBot Identity的Namespace,或者填Robot Namespace Override。Command Topic Override非空时,它替代整个话题。运行时用
Get Resolved Command Topic查看实际订阅的话题。 -
确定谁来执行指令
Target Component为空时,Actor 本身实现了UBot Velocity Commandable就交给 Actor,否则交给第一个实现它的组件。也可以在Target Component里指定一个组件。Actor 上找不到目标不是错误:组件照常解码、触发事件并运行超时,指令只在蓝图里处理。
-
让载具实现接口
在载具或无人机的蓝图里,打开「Class Settings」,在「Interfaces」里添加
UBot Velocity Commandable,然后实现两个函数:Apply Velocity Command:收到Command,返回false表示拒绝这条指令。Stop Motion:停车。
Command是机体系的 UE 轴向(X 向前、Y 向右、Z 向上),线速度单位 m/s,角速度单位 rad/s,转向用 UE 的约定:+Z 是向右偏航。油门、转向映射和控制器都写在这两个函数里。 -
从 ROS 2 发指令
终端窗口 ros2 topic pub -r 10 /robot1/cmd_vel geometry_msgs/msg/Twist "{linear: {x: 0.5}, angular: {z: 0.2}}"命令里的
robot1换成你的命名空间。
| 属性 | 默认值 | 作用 |
|---|---|---|
Auto Start Receiver |
true | Begin Play 时订阅;关闭后调用 Restart Command Receiver |
Robot Namespace Override |
空 | 空则用 uBot Identity 的命名空间;只填 / 表示根命名空间,话题是 /cmd_vel |
Command Topic Override |
空 | 非空时替代 /<namespace>/cmd_vel,缺少前导 / 会补上 |
Target Component |
空 | 接收指令的组件,必须实现 UBot Velocity Commandable;空则自动查找 |
Command Timeout Seconds |
0.5 s | 超过这么久(仿真时间)没有新指令,就让目标停车;0 关闭超时 |
Max Linear Speed Meters Per Second |
0 | 线速度的上限(向量模长),保持方向;0 表示不限制 |
Max Angular Speed Radians Per Second |
0 | 角速度的上限(向量模长),保持轴向;0 表示不限制 |
消息如何转换
Section titled “消息如何转换”Twist 的 linear 和 angular 都在机体系,从 ROS 约定换成 UE 的轴向:
| 量 | ROS Twist |
UBot Velocity Command |
|---|---|---|
| 线速度 | (x, y, z),m/s |
(x, -y, z),m/s |
| 角速度 | (x, y, z),rad/s |
(-x, y, -z),rad/s |
ROS 的 angular.z = +0.25(向左转)对应 UE 的 Z = -0.25,因为 UE 里 +Z 是向右偏航。结果的 Source 是 ROS,Timestamp Seconds 是收到指令时的仿真时间。
处理顺序是:解码 → 换算 → 限速 → 交给目标的 Apply Velocity Command → 触发 On Velocity Command。畸形的消息,或含非有限值的消息,会被丢弃并触发 On Command Error。
订阅的 QoS
Section titled “订阅的 QoS”组件用 best_effort / volatile / 深度 10 订阅 cmd_vel。发布方是 reliable 还是 best_effort 都能匹配,ros2 topic pub 默认的 reliable 发布者可以直接用。
| 节点 | 作用 |
|---|---|
On Velocity Command |
每条有效指令换算、限速并交给目标之后触发,有没有目标都触发;Command 是结果 |
On Command Timeout |
每次超时触发一次,在目标收到 Stop Motion 之后 |
On Command Error |
订阅失败、消息畸形或含非有限值、目标不可用或拒绝了指令;Error Message 是原因 |
Is Command Receiver Ready |
已订阅时为 true,与桥是否连上无关 |
Is Command Active |
从收到有效指令到超时为 true;超时关闭时,收到过指令后一直为 true |
Get Last Command |
最近一条有效指令(限速之后),收到第一条之前全为 0 |
Get Resolved Command Topic |
正在订阅的话题;没有订阅时,是下一次启动会用的话题 |
Get Command Target |
指令交给的对象,没有目标时为空 |
Get Command Error |
最近一条错误的文字 |
Set Target Component |
用一个组件直接替换 Target Component;传空则恢复自动查找 |
Restart Command Receiver |
取消订阅后用当前设置重新订阅,超时计时继续 |
Stop Command Receiver |
取消订阅;已经生效的指令仍然按时超时 |
- 超过
Command Timeout Seconds的仿真时间没有新指令,目标收到一次Stop Motion,随后触发On Command Timeout。 - 暂停时仿真时间不前进,超时也不会触发。组件
End Play时若指令仍然有效,同样让目标Stop Motion。 - ROS 2 端要持续发布:发布间隔超过
Command Timeout Seconds,车就会停。上面的例子用-r 10,即 10 Hz。
连线:
- On Command Timeout (CmdVel) 的 执行,连到 Print String 的 执行
- On Command Error (CmdVel) 的 执行,连到 Print String 的 执行
- On Command Error (CmdVel) 的 Error Message,连到 Print String 的 In String
On Command Timeout (CmdVel)
uBot ROS Velocity Command · UBotROS
每次超时触发一次,在目标收到 Stop Motion 之后。
输出
- 执行
查看参考UUBotROSVelocityCommandComponent.OnCommandTimeout
Print String
UE 引擎 · 中文界面:打印字符串
Prints a string to the log, and optionally, to the screen If Print To Log is true, it will be visible in the Output Log window. Otherwise it will be logged only as 'Verbose', so it generally won't show up.
输入
- 执行
- In String
String - Print to Screen
Boolean - Print to Log
Boolean - Text Color
Linear Color结构体 - Duration
Float - Key
Name
输出
- 执行
查看参考UKismetSystemLibrary.PrintString
On Command Error (CmdVel)
uBot ROS Velocity Command · UBotROS
订阅失败、消息畸形或含非有限值、目标不可用或拒绝了指令时触发,Error Message 是原因。
输出
- 执行
- Error Message
String
查看参考UUBotROSVelocityCommandComponent.OnCommandError
Print String
UE 引擎 · 中文界面:打印字符串
Prints a string to the log, and optionally, to the screen If Print To Log is true, it will be visible in the Output Log window. Otherwise it will be logged only as 'Verbose', so it generally won't show up.
输入
- 执行
- In String
String - Print to Screen
Boolean - Print to Log
Boolean - Text Color
Linear Color结构体 - Duration
Float - Key
Name
输出
- 执行
查看参考UKismetSystemLibrary.PrintString
- 组件只做解码、换算、限速、分发和超时,不含控制逻辑。
- 目标拒绝指令(
Apply Velocity Command返回 false)时,只报告一次。 - 订阅在
Begin Play时建立,不等桥连上;桥连上之后订阅才生效。 - 旧版
Agent ROS Vehicle Command和Agent ROS Drone Command里的比例速度控制器、油门 / 刹车 / 转向映射和失效制动,不在 uBotROS 里,要写在目标里。这两个组件没有重定向,需要手工替换,见从旧插件迁移。
- uBot ROS Velocity Command:全部节点和属性。
- UBot Velocity Commandable:接口的两个函数。
- UBot Velocity Command:结构体的字段。
- 插件之间怎么对接:uBot 的几个公共接口。
- 坐标系与单位:UE 与 ROS 的轴向换算。